RWLT

A precise solution for tracking an underwater object
Underwater Communication and Navigation Laboratory
Home / Products / Navigation / RWLT system

The RWLT system is the easiest to use and, at the same time, the most precise solution for tracking an underwater object

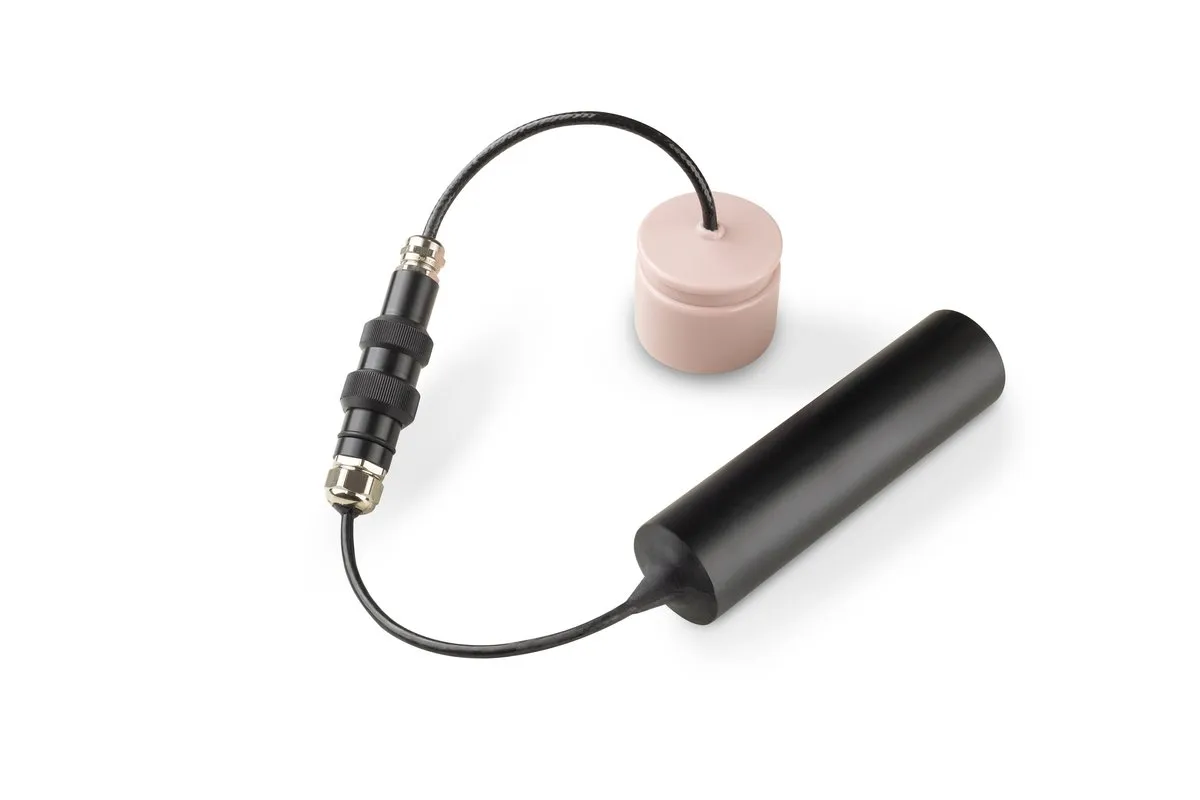
The system requires no calibration and no integration: simply place the autonomous RWLT Pinger beacon on the underwater object (ROV, AUV, diver, etc.), and four navigation buoys, RWLT GIB, on the surface of the water. This configuration lets you track the underwater object's movement in 3D in real time: absolute geographic coordinates and depth

  • Real-time tracking of an underwater object's position (divers, ROVs, AUVs, etc.)
  • Determining the underwater object's course
  • Assistance in guiding the underwater object to a surface control point and back
Want access to detailed technical documentation for the device?

Documentation
Want access to detailed technical documentation for the device?
01

Navigation and voice communication

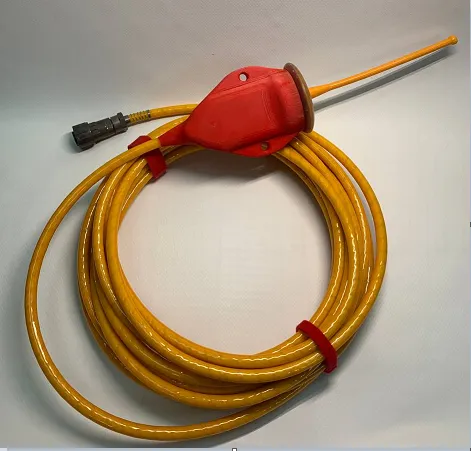
A distinctive feature of the system is that it can use the RedPhone-DX diver telephone station as a pinger, combining two-way voice communication and navigation.

When working with a pinger, the uNav RWLT RF Dongle navigation receiver emulates the protocol of standard GNSS receivers, and can be connected to any software that displays a GNSS receiver's position on a map, such as Google Earth, SAS.Planet, etc.

02

System composition

The minimum system composition is four RWLT GIB hydroacoustic buoys and one transmitting device, depending on the task:

  • If the diver needs navigation data along with voice communication, the RedPhone-DX diver telephone station is used as the transmitting device. The diver's geoposition is determined the moment they release the PTT button, i.e. when they finish a voice transmission
  • If you need to locate a remotely operated vehicle (ROV) or a diver without voice communication, the RWLT Pinger beacon is used. The pinger operates autonomously, and the geoposition of the object it is mounted on is updated every two seconds
03

When working with a pinger

Simply connect the navigation receiver to any chartplotter that supports NMEA0183 RMC and GGA messages. In this mode you get:

  • the geographic position of the object the pinger is mounted on
  • the object's course

The open-source uNav application additionally shows:

  • the positions of the navigation buoys and the charge of their built-in power sources
  • the course and range to a reference point: one of the four buoys, the built-in uNav RWLT RF Dongle navigation receiver, or a point with arbitrary coordinates
  • water temperature
  • the pinger's supply voltage
04

When working with RedPhone-DX diver stations

This requires the open-source uTrackDiver application. It shows the positions of up to 255 divers, determined at the end of each voice transmission from the diver.

05

Distinctive features

  • Operation in absolute geographic coordinates
  • A floating base of four hydroacoustic buoys can track both the RWLT Pinger beacon and the RedPhone-DX diver telephone station
  • No preliminary setup or calibration of the system or its components is required
  • No data link is required between the object and the pinger: the pinger is mechanically mounted on the underwater carrier
  • The calculated position of the underwater object is passed to third-party software over a serial port using the NMEA0183 protocol
  • Recording of the underwater object's movement track
06

Geometric limitations

  • From each buoy to every other buoy there should be no more than 1500 meters and no less than 30 meters
  • The buoys should be arranged in a convex quadrangle so that its sides are approximately equal and differ by no more than 2 times
  • The maximum diving depth of the pinger should not exceed the dimensions of the navigation base
  • The greatest accuracy of the system is achieved within the buoy figure, and operation should always begin within this figure. Going beyond the figure is possible, but accuracy may decrease significantly as the positioned object moves away from the buoy figure

Submit Your Inquiry

Learn more about digital wireless underwater data transmission systems
Buy UCNL products